Field notes / Experiment guide
Can we trust the growth measurements?
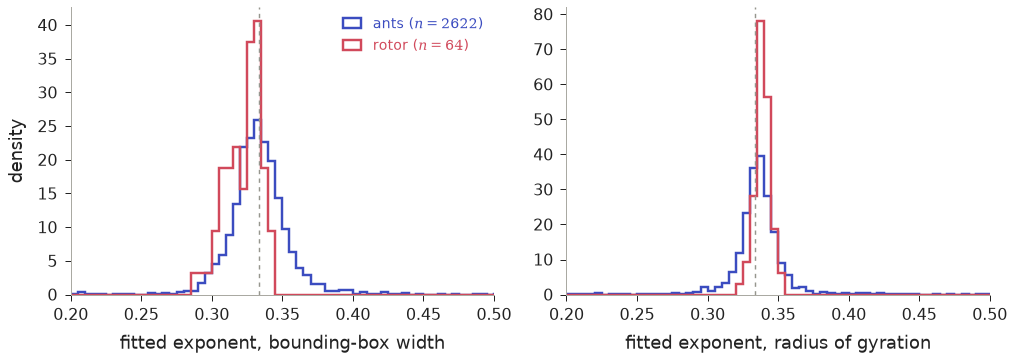
A fitted exponent can look convincing even when the observation window is biased. How do our instruments behave on walkers with known comparison behaviour?
New to these ants? Start here.
An ant moves on a grid of coloured squares. Each colour tells it to turn left (L) or right (R). It advances that square to the next colour, then steps forward. A rule such as RLR is the list of turns, starting at colour zero. On a blank grid the same rule always makes the same trajectory.
Territory means every cell visited so far. Its boundary consists of visited cells with an unvisited neighbour. A highway is a repeating pattern of motion that carries the ant away. A tether means repeated returns to a small home region.
Growing like the cube root of time means taking eight times as many steps to double a linear size. The rotor walker is a comparison model that follows and rotates arrows stored on cells. A seed makes a random starting pattern reproducible; the ant itself can still move deterministically.
We distinguish c, the chance of discovering a cell per boundary step, from kappa (κ), time at the boundary normalized by perimeter divided by area. Explaining their values is harder than using them to account for growth.
A closer look
The idea under test
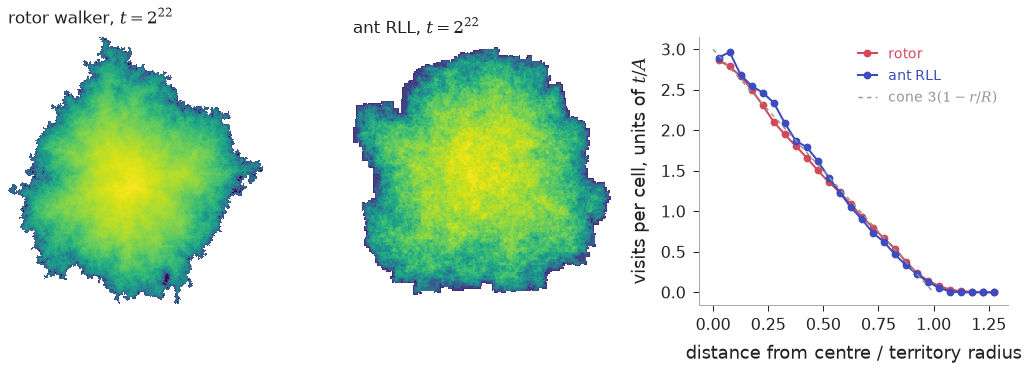
A rotor walker should recover cube-root radius growth, while a random walk supplies a different-growth negative control.
What we learned
The calibration records the finite-window behaviour of the growth, perimeter and shape estimators. It is the reference against which ant fits are judged.
What this leaves open
An estimator that works on the rotor is not automatically unbiased on every ant. Changed windows and estimators require fresh calibration.
Read the evidence and reproduction recipe ↗
Inside the experiment
Methods, registered predictions, exact commands and saved analysis. These are the working research documents; expand them for the detail behind the introduction.
Methods and original experiment record
calib-instrument-calibration
Migrated legacy investigation (2026-10-14). Its files used to sit in the flat data/ directory (and calib/, occ/, snaps/, dumps*, knock* where listed) with the label prefix below; experiments/_migration/map.tsv gives the exact old -> new path of every file. This stub was generated from file names and script docstrings. It is not the original write-up: the question, timestamped hypotheses, commands and results are in notes/ (mainly notes/frontier-results.md, notes/frontier-status.md, notes/research-frontier*.md; search for the label), and the producing command is usually in the script docstring or a run_*.sh here.
Old labels / prefixes: alt, calib, calibrate, checkpoints, contour, done, exactly4, long, short
Scripts
scripts/calibrate.py: Calibration part A: put rotor walkers (true range exponent 2/3, width 1/3,scripts/contour_chunks.py: Contour radius of nbar = 1 at N = 1e6, per chunk of seeds, with twoscripts/contour_verdict.py: Combine the contour-radius runs (main generator and alternative generator)
Results
17 entries in results/ (0 are .log/.done markers); csv/json/txt outputs, *_stats.txt hold the summaries quoted in the notes.
Notebook
No committed Jupyter notebook is available for this experiment yet.